스모크 10칸 (MolmoBot) — find 5칸
2026-09-18 · job 135872 · 본 런과 같은 스냅샷·설정(가드 B 끔) · 5칸 · 성공 1 · API $0.494
요약 — 같은 find 5칸을 MolmoBot place_oc@10000으로(이전 π0.5 런 2/5). 결과 1/5 성공(vis-pure 국자 5턴), $0.494, 잡 54m.
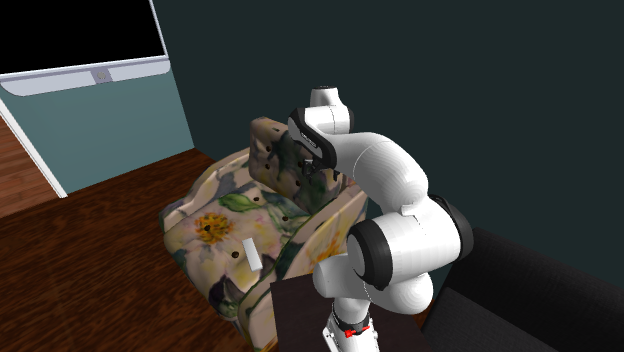
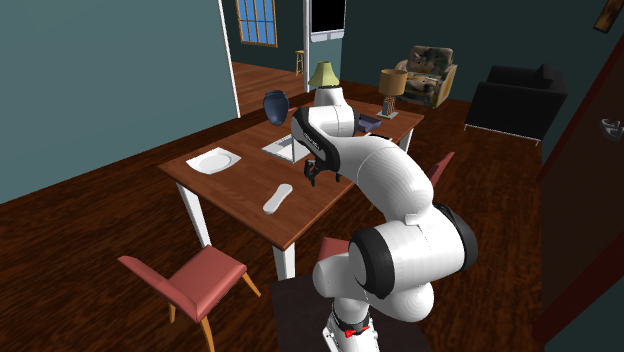
- frames 열쇠고리(서랍):
open dresser를 T18에 성공(π0.5는 0/13) → 서랍 안 열쇠고리 pick 3회 실패 → 예산 초과. open 첫 성공 사례. - textlog 리모컨 전부(multi): T4에 둘 다 집어 목표 충족(goal_met_turn=4) 했는데 done 없이 재시작 루프(같은 리모컨 재-pick 성공 9회를 "아직 못 들었다"고 읽음) → 예산 초과.
unaware_success, overrun 17. - vis-pure 국자: 성공(5턴).
- blind 리모컨: pick 1회 실패 뒤 "집었다" done →
false_done, 2턴 실패(π0.5 런에선 12턴 성공 — VLM 변동). 이 칸도twin_nearby. - rf-v3 칼(쌍둥이): 또 GT `_2` 대신 0.35 m 옆 `_1`로 해석 → 8회 시도 후 "들었다" done → false_done. VLM은 T4에 "흰 버터나이프를 대신 잡았다"고 두 개를 인지했지만 인스턴스를 지정할 수단이 없음.
find 5칸 중 2칸이 쌍둥이 셀(본 런 20.2%) — 제외 여부 결정 필요.
플랜 요약
| # | 전략 | 질의 | 결과 | 종료 | 턴 | 스텝 | $ |
|---|---|---|---|---|---|---|---|
| 1 | frames-uniform | Pick up the key chain I moved earlier | 실패 | budget_exhausted | 21 | 2500 | $0.267 |
| 2 | textlog | Pick up all the remote controls I moved earlier | 실패 | budget_exhausted | 21 | 3348 | $0.106 |
| 3 | rollforward-vis-pure | Pick up the ladle | 성공 | done | 5 | 520 | $0.058 |
| 4 | blind | Pick up the remote control I moved earlier | 실패 | done | 2 | 128 | $0.008 |
| 5 | rollforward-v3 | Pick up the knife | 실패 | done | 10 | 1397 | $0.055 |
플랜 1 — frames-uniform · Pick up the key chain I moved earlier
| 질의 | Pick up the key chain I moved earlier |
| 전략 | frames-uniform · v1_train_2224__2 |
| 결과 | 실패 종료 budget_exhausted · 21/30턴 · 2500/2500스텝 · $0.267 (21회) |
| navigate / pick 횟수 | 4 / 8 · 재질의 0 |
| GT 물체를 든 횟수 | 0/1 |
초기 계획(읽기 답)
- pick up the key chain — on the dresser in the bedroom
턴 전수 펼치기 (21턴)
턴 0
navigate도착 경로 13.643841138310123 m · 470 스텝
에이전트의 이유
According to the plan, the key chain that was moved earlier is on the dresser in the bedroom. I need to navigate to the dresser in the bedroom to pick it up.
According to the plan, the key chain that was moved earlier is on the dresser in the bedroom. I need to navigate to the dresser in the bedroom to pick it up.
| skill | navigate |
| category / surface / room | None / None / bedroom |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_5 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "According to the plan, the key chain that was moved earlier is on the dresser in the bedroom. I need to navigate to the dresser in the bedroom to pick it up.", "next": {"skill": "navigate", "category": "key chain", "surface": "dresser", "room": "bedroom"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 9}
턴 1
pick실패 128 스텝 · 그리퍼 전환 6
에이전트의 이유
We are in front of the dresser in the bedroom where the key chain is located. Attempting to pick up the key chain.
We are in front of the dresser in the bedroom where the key chain is located. Attempting to pick up the key chain.
| skill | pick |
| category / surface / room | key chain / None / None |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the key chain |
VLM 원문 응답
```json
{"note": null, "reasoning": "We are in front of the dresser in the bedroom where the key chain is located. Attempting to pick up the key chain.", "next": {"skill": "pick", "category": "key chain", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 2
open실패 128 스텝 · 그리퍼 전환 8
에이전트의 이유
The key chain is inside the dresser drawer in the bedroom. The previous open command did not fully open the drawer, so I will retry opening the dresser drawer.
The key chain is inside the dresser drawer in the bedroom. The previous open command did not fully open the drawer, so I will retry opening the dresser drawer.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain is inside the dresser drawer in the bedroom. The previous open command did not fully open the drawer, so I will retry opening the dresser drawer.", "next": {"skill": "open", "category": "dresser", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 3
navigate도착 경로 0.18340940271810552 m · 64 스텝
에이전트의 이유
The plan states the key chain is on/in the dresser in the bedroom. I will navigate to the dresser in the bedroom targeting the key chain.
The plan states the key chain is on/in the dresser in the bedroom. I will navigate to the dresser in the bedroom targeting the key chain.
| skill | navigate |
| category / surface / room | None / None / bedroom |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "The plan states the key chain is on/in the dresser in the bedroom. I will navigate to the dresser in the bedroom targeting the key chain.", "next": {"skill": "navigate", "category": "key chain", "surface": "dresser", "room": "bedroom"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 4
navigate도착 경로 0.301410647230371 m · 37 스텝
에이전트의 이유
Navigate to the dresser in the bedroom to get a clear view and reach the key chain.
Navigate to the dresser in the bedroom to get a clear view and reach the key chain.
| skill | navigate |
| category / surface / room | None / None / bedroom |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "Navigate to the dresser in the bedroom to get a clear view and reach the key chain.", "next": {"skill": "navigate", "category": "key chain", "surface": "dresser", "room": "bedroom"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 5
pick실패 128 스텝 · 그리퍼 전환 8
에이전트의 이유
The robot is in front of the dresser where the key chain is located. Now execute pick on the key chain.
The robot is in front of the dresser where the key chain is located. Now execute pick on the key chain.
| skill | pick |
| category / surface / room | key chain / None / None |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the key chain |
VLM 원문 응답
```json
{"note": null, "reasoning": "The robot is in front of the dresser where the key chain is located. Now execute pick on the key chain.", "next": {"skill": "pick", "category": "key chain", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 6
open실패 128 스텝 · 그리퍼 전환 6
에이전트의 이유
The key chain is likely inside the dresser drawer (seen open earlier). I need to open the dresser drawer to access it.
The key chain is likely inside the dresser drawer (seen open earlier). I need to open the dresser drawer to access it.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain is likely inside the dresser drawer (seen open earlier). I need to open the dresser drawer to access it.", "next": {"skill": "open", "category": "dresser", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 7
open실패 128 스텝 · 그리퍼 전환 8
에이전트의 이유
The key chain is inside the dresser drawer, which is currently closed. I need to open the dresser first to access it.
The key chain is inside the dresser drawer, which is currently closed. I need to open the dresser first to access it.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain is inside the dresser drawer, which is currently closed. I need to open the dresser first to access it.", "next": {"skill": "open", "category": "dresser", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 8
pick실패 128 스텝 · 그리퍼 전환 8
에이전트의 이유
The key chain is on/in the dresser in the bedroom. I am currently in position in front of the dresser. I will attempt to pick the key chain.
The key chain is on/in the dresser in the bedroom. I am currently in position in front of the dresser. I will attempt to pick the key chain.
| skill | pick |
| category / surface / room | key chain / None / None |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the key chain |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain is on/in the dresser in the bedroom. I am currently in position in front of the dresser. I will attempt to pick the key chain.", "next": {"skill": "pick", "category": "key chain", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 9
open실패 128 스텝 · 그리퍼 전환 11
에이전트의 이유
The key chain is inside the drawer of the dresser in the bedroom. I need to open the dresser drawer to access it.
The key chain is inside the drawer of the dresser in the bedroom. I need to open the dresser drawer to access it.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain is inside the drawer of the dresser in the bedroom. I need to open the dresser drawer to access it.", "next": {"skill": "open", "category": "dresser", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 10
pick실패 128 스텝 · 그리퍼 전환 9
에이전트의 이유
The drawer of the dresser has been opened. I will now attempt to pick the key chain from the dresser.
The drawer of the dresser has been opened. I will now attempt to pick the key chain from the dresser.
| skill | pick |
| category / surface / room | key chain / None / None |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the key chain |
VLM 원문 응답
```json
{"note": null, "reasoning": "The drawer of the dresser has been opened. I will now attempt to pick the key chain from the dresser.", "next": {"skill": "pick", "category": "key chain", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 11
open실패 128 스텝 · 그리퍼 전환 2
에이전트의 이유
The key chain was previously placed inside the dresser drawer. I am currently in front of the dresser and need to open it to access the key chain.
The key chain was previously placed inside the dresser drawer. I am currently in front of the dresser and need to open it to access the key chain.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain was previously placed inside the dresser drawer. I am currently in front of the dresser and need to open it to access the key chain.", "next": {"skill": "open", "category": "dresser", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 12
pick실패 128 스텝 · 그리퍼 전환 6
에이전트의 이유
I need to pick up the key chain located at the dresser in the bedroom. I am currently in front of the dresser, so I will attempt to pick the key chain.
I need to pick up the key chain located at the dresser in the bedroom. I am currently in front of the dresser, so I will attempt to pick the key chain.
| skill | pick |
| category / surface / room | key chain / None / None |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the key chain |
VLM 원문 응답
```json
{"note": null, "reasoning": "I need to pick up the key chain located at the dresser in the bedroom. I am currently in front of the dresser, so I will attempt to pick the key chain.", "next": {"skill": "pick", "category": "key chain", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 13
navigate도착 경로 0.18500414268692403 m · 43 스텝
에이전트의 이유
The plan indicates the key chain is on/in the dresser in the bedroom. I will navigate directly to the dresser in the bedroom to locate and pick the key chain.
The plan indicates the key chain is on/in the dresser in the bedroom. I will navigate directly to the dresser in the bedroom to locate and pick the key chain.
| skill | navigate |
| category / surface / room | None / None / bedroom |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "The plan indicates the key chain is on/in the dresser in the bedroom. I will navigate directly to the dresser in the bedroom to locate and pick the key chain.", "next": {"skill": "navigate", "category": "key chain", "surface": "dresser", "room": "bedroom"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
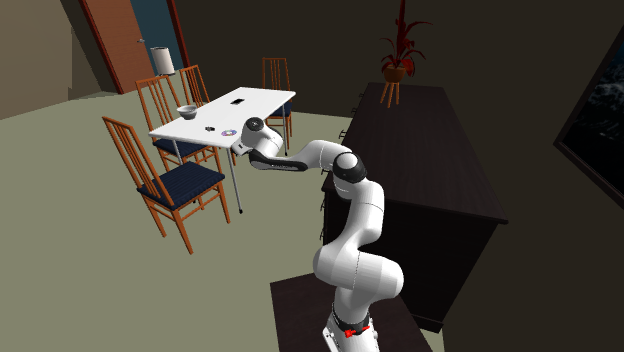
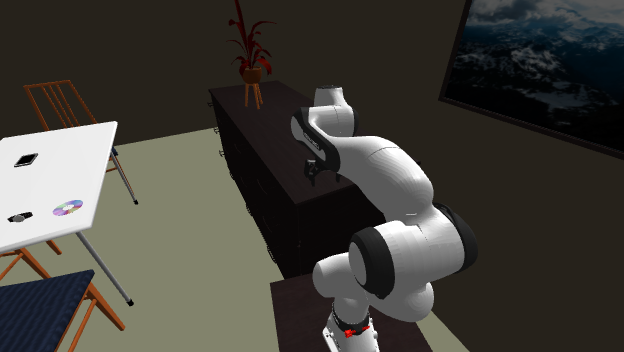
턴 14
open실패 128 스텝 · 그리퍼 전환 5
에이전트의 이유
I have navigated to the dresser in the bedroom. The key chain is inside the drawer, so I need to open the dresser drawer first.
I have navigated to the dresser in the bedroom. The key chain is inside the drawer, so I need to open the dresser drawer first.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
```json
{
  "note": null,
  "reasoning": "I have navigated to the dresser in the bedroom. The key chain is inside the drawer, so I need to open the dresser drawer first.",
  "next": {
    "skill": "open",
    "category": "dresser",
    "surface": null,
    "room": null
  }
}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 15
open실패 128 스텝 · 그리퍼 전환 7
에이전트의 이유
The key chain is inside the dresser drawer. I need to open the dresser drawer to access it.
The key chain is inside the dresser drawer. I need to open the dresser drawer to access it.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain is inside the dresser drawer. I need to open the dresser drawer to access it.", "next": {"skill": "open", "category": "dresser", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}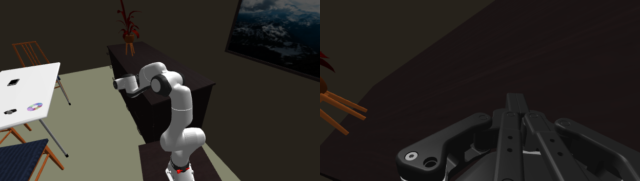
턴 16
open성공 52 스텝 · 그리퍼 전환 6
에이전트의 이유
The key chain is inside the dresser drawer in the bedroom, but the drawer is currently closed. I need to open the dresser first.
The key chain is inside the dresser drawer in the bedroom, but the drawer is currently closed. I need to open the dresser first.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
{"note": null, "reasoning": "The key chain is inside the dresser drawer in the bedroom, but the drawer is currently closed. I need to open the dresser first.", "next": {"skill": "open", "category": "dresser", "surface": null, "room": null}}이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}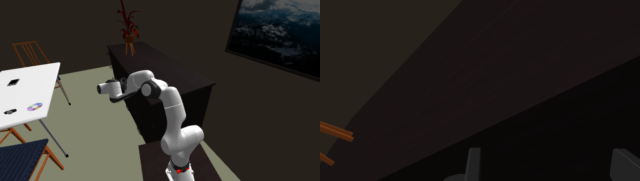
턴 17
open성공 0 스텝 · 그리퍼 전환 0 · vacuous(스텝 0)
에이전트의 이유
The key chain is inside the dresser drawer, which is currently closed. I need to open the dresser drawer first.
The key chain is inside the dresser drawer, which is currently closed. I need to open the dresser drawer first.
| skill | open |
| category / surface / room | dresser / None / None |
| 접지된 object_id | chestofdrawers_11a5283cbdd2aaa77d17322d7a00ec20_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Open the dresser. |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain is inside the dresser drawer, which is currently closed. I need to open the dresser drawer first.", "next": {"skill": "open", "category": "dresser", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 18
pick실패 128 스텝 · 그리퍼 전환 12
에이전트의 이유
The robot is standing in front of the dresser where the key chain is located. Attempting to pick the key chain.
The robot is standing in front of the dresser where the key chain is located. Attempting to pick the key chain.
| skill | pick |
| category / surface / room | key chain / None / None |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the key chain |
VLM 원문 응답
```json
{"note": null, "reasoning": "The robot is standing in front of the dresser where the key chain is located. Attempting to pick the key chain.", "next": {"skill": "pick", "category": "key chain", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 9}
턴 19
pick실패 128 스텝 · 그리퍼 전환 6
에이전트의 이유
The key chain is inside the open dresser drawer in front of the robot. I will command pick to grasp and lift the key chain.
The key chain is inside the open dresser drawer in front of the robot. I will command pick to grasp and lift the key chain.
| skill | pick |
| category / surface / room | key chain / None / None |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the key chain |
VLM 원문 응답
```json
{"note": null, "reasoning": "The key chain is inside the open dresser drawer in front of the robot. I will command pick to grasp and lift the key chain.", "next": {"skill": "pick", "category": "key chain", "surface": "dresser", "room": "bedroom"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
턴 20
pick실패 42 스텝 · 그리퍼 전환 2
에이전트의 이유
The goal is to pick up the key chain on/in the dresser in the bedroom. I am in front of the dresser; I will command pick on the key chain.
The goal is to pick up the key chain on/in the dresser in the bedroom. I am in front of the dresser; I will command pick on the key chain.
| skill | pick |
| category / surface / room | key chain / None / None |
| 접지된 object_id | keyring_38a2d58fb440223e3e220a82f38a2261_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the key chain |
VLM 원문 응답
```json
{"note": null, "reasoning": "The goal is to pick up the key chain on/in the dresser in the bedroom. I am in front of the dresser; I will command pick on the key chain.", "next": {"skill": "pick", "category": "key chain", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames sampled at even intervals over everything you have observed so far:', 'Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the key chain — on the dresser in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, armchair, bed, book, bottle, bowl, bread, cell phone, chair, countertop, credit card, dining table, dish sponge, dresser, egg, faucet, floor lamp, fork, fridge, garbage can, house plant, key chain, knife, ladle, laptop, mug, painting, paper towel roll, pen, pencil, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, sofa, spatula, spray bottle, statue, teddy bear, television, toaster, toilet, toilet paper, tomato, tv stand, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the key chain I moved earlier', 'Reply with the JSON object only.'], 'n_images': 12}
플랜 2 — textlog · Pick up all the remote controls I moved earlier
| 질의 | Pick up all the remote controls I moved earlier |
| 전략 | textlog · v1_train_2788__2 |
| 결과 | 실패 종료 budget_exhausted · 21/34턴 · 3348/3000스텝 · $0.106 (21회) |
| navigate / pick 횟수 | 7 / 14 · 재질의 0 |
| GT 물체를 든 횟수 | 2/2 · 예산 안이면 성공(success_nobudget) |
초기 계획(읽기 답)
- pick up the remote control — on the armchair in the living room
- pick up the remote control — on the dining table in the living room
턴 전수 펼치기 (21턴)
턴 0
navigate도착 경로 8.33569081596729 m · 323 스텝
에이전트의 이유
According to the plan, the first remote control to pick up is on the armchair in the living room. I need to navigate there first.
According to the plan, the first remote control to pick up is on the armchair in the living room. I need to navigate there first.
| skill | navigate |
| category / surface / room | None / None / living room |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "According to the plan, the first remote control to pick up is on the armchair in the living room. I need to navigate there first.", "next": {"skill": "navigate", "category": "remote control", "surface": "armchair", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 1}
턴 1
pick성공 98 스텝 · 그리퍼 전환 2
에이전트의 이유
I have navigated to the armchair in the living room where remote control #1 is located. I will now pick it up.
I have navigated to the armchair in the living room where remote control #1 is located. I will now pick it up.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "I have navigated to the armchair in the living room where remote control #1 is located. I will now pick it up.", "next": {"skill": "pick", "category": "remote control", "surface": "armchair", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 2
navigate도착 경로 8.543603979649497 m · 304 스텝
에이전트의 이유
The remote control on the armchair has been picked up. Now I will proceed to pick up the second remote control on the dining table in the living room.
The remote control on the armchair has been picked up. Now I will proceed to pick up the second remote control on the dining table in the living room.
| skill | navigate |
| category / surface / room | None / None / living room |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "The remote control on the armchair has been picked up. Now I will proceed to pick up the second remote control on the dining table in the living room.", "next": {"skill": "navigate", "category": "remote control", "surface": "dining table", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
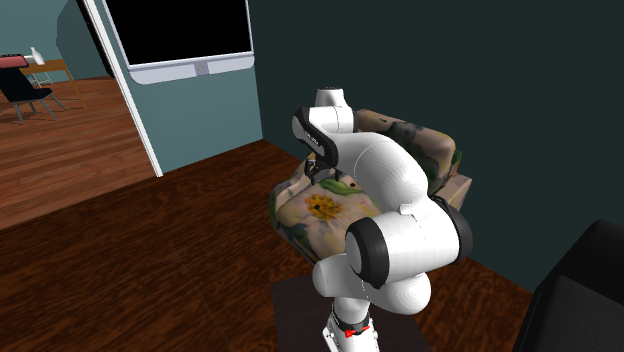
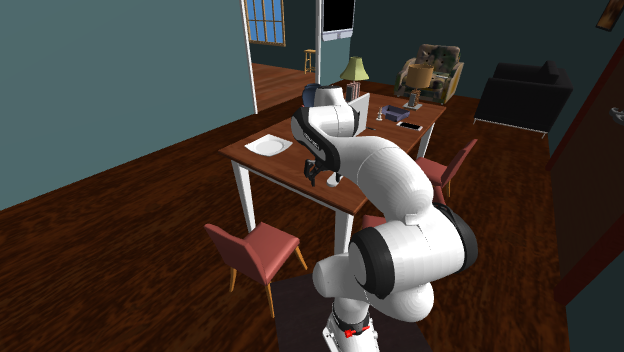
턴 3
pick성공 87 스텝 · 그리퍼 전환 4
에이전트의 이유
I have navigated to the dining table in the living room where remote control #2 was placed. Now I will pick it up.
I have navigated to the dining table in the living room where remote control #2 was placed. Now I will pick it up.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "I have navigated to the dining table in the living room where remote control #2 was placed. Now I will pick it up.", "next": {"skill": "pick", "category": "remote control", "surface": "dining table", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 4
navigate도착 경로 9.152014200411015 m · 389 스텝
에이전트의 이유
I need to pick up remote control #1 from the armchair in the living room first according to the plan.
I need to pick up remote control #1 from the armchair in the living room first according to the plan.
| skill | navigate |
| category / surface / room | None / None / living room |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "I need to pick up remote control #1 from the armchair in the living room first according to the plan.", "next": {"skill": "navigate", "category": "remote control", "surface": "armchair", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 5
pick성공 80 스텝 · 그리퍼 전환 0
에이전트의 이유
I have navigated to the armchair in the living room where remote control #1 is located. I will now pick it up.
I have navigated to the armchair in the living room where remote control #1 is located. I will now pick it up.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "I have navigated to the armchair in the living room where remote control #1 is located. I will now pick it up.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 6
pick성공 98 스텝 · 그리퍼 전환 2
에이전트의 이유
The gripper is positioned around the remote control on the armchair but has not yet grasped and lifted it. I will continue the pick subgoal.
The gripper is positioned around the remote control on the armchair but has not yet grasped and lifted it. I will continue the pick subgoal.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "The gripper is positioned around the remote control on the armchair but has not yet grasped and lifted it. I will continue the pick subgoal.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 7
pick성공 12 스텝 · 그리퍼 전환 0
에이전트의 이유
The gripper has closed around the remote control on the armchair, but it has not been fully lifted yet. I will continue the pick subgoal.
The gripper has closed around the remote control on the armchair, but it has not been fully lifted yet. I will continue the pick subgoal.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "The gripper has closed around the remote control on the armchair, but it has not been fully lifted yet. I will continue the pick subgoal.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 8
pick성공 94 스텝 · 그리퍼 전환 2
에이전트의 이유
The gripper is positioned around the remote control on the armchair; continuing the pick to grasp and lift it.
The gripper is positioned around the remote control on the armchair; continuing the pick to grasp and lift it.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "The gripper is positioned around the remote control on the armchair; continuing the pick to grasp and lift it.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 9
pick성공 13 스텝 · 그리퍼 전환 0
에이전트의 이유
The gripper is positioned around remote control #1 on the armchair in the living room; repeating pick to complete grasping and lifting.
The gripper is positioned around remote control #1 on the armchair in the living room; repeating pick to complete grasping and lifting.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "The gripper is positioned around remote control #1 on the armchair in the living room; repeating pick to complete grasping and lifting.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 10
navigate도착 경로 9.694318189256585 m · 354 스텝
에이전트의 이유
The remote control on the armchair has been successfully picked up. Now navigate to the dining table in the living room to pick up the second remote control.
The remote control on the armchair has been successfully picked up. Now navigate to the dining table in the living room to pick up the second remote control.
| skill | navigate |
| category / surface / room | None / None / living room |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "The remote control on the armchair has been successfully picked up. Now navigate to the dining table in the living room to pick up the second remote control.", "next": {"skill": "navigate", "category": "remote control", "surface": "dining table", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 11
pick성공 47 스텝 · 그리퍼 전환 2
에이전트의 이유
I am in front of the dining table in the living room with the remote control in reach. I will pick it up.
I am in front of the dining table in the living room with the remote control in reach. I will pick it up.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "I am in front of the dining table in the living room with the remote control in reach. I will pick it up.", "next": {"skill": "pick", "category": "remote control", "surface": "dining table", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}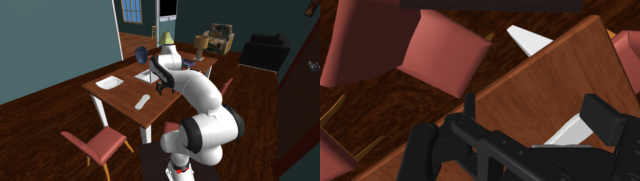
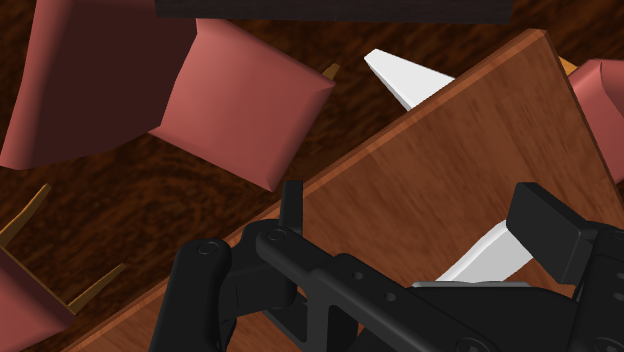
턴 12
pick성공 57 스텝 · 그리퍼 전환 0
에이전트의 이유
The gripper is aligned with the remote control on the dining table; continuing the pick action to lift it.
The gripper is aligned with the remote control on the dining table; continuing the pick action to lift it.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "The gripper is aligned with the remote control on the dining table; continuing the pick action to lift it.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 13
pick성공 12 스텝 · 그리퍼 전환 0
에이전트의 이유
The gripper is positioned right in front of the remote control on the dining table but has not grasped and lifted it yet. Continuing the pick action.
The gripper is positioned right in front of the remote control on the dining table but has not grasped and lifted it yet. Continuing the pick action.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "The gripper is positioned right in front of the remote control on the dining table but has not grasped and lifted it yet. Continuing the pick action.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 14
navigate도착 경로 9.107733345750544 m · 353 스텝
에이전트의 이유
I need to pick up the remote controls moved earlier. First, I will navigate to the armchair in the living room to pick up the remote control located there.
I need to pick up the remote controls moved earlier. First, I will navigate to the armchair in the living room to pick up the remote control located there.
| skill | navigate |
| category / surface / room | None / None / living room |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "I need to pick up the remote controls moved earlier. First, I will navigate to the armchair in the living room to pick up the remote control located there.", "next": {"skill": "navigate", "category": "remote control", "surface": "armchair", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 15
pick성공 111 스텝 · 그리퍼 전환 4
에이전트의 이유
I am in front of the armchair in the living room with the remote control visible on it. I will pick it up.
I am in front of the armchair in the living room with the remote control visible on it. I will pick it up.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "I am in front of the armchair in the living room with the remote control visible on it. I will pick it up.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}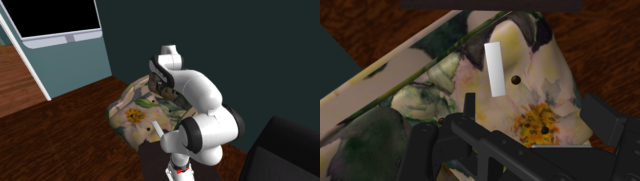
턴 16
navigate도착 경로 9.294441435864094 m · 360 스텝
에이전트의 이유
The remote control on the armchair has been successfully grasped and lifted. Now, navigate to the dining table in the living room to pick up the second remote control.
The remote control on the armchair has been successfully grasped and lifted. Now, navigate to the dining table in the living room to pick up the second remote control.
| skill | navigate |
| category / surface / room | None / None / living room |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "The remote control on the armchair has been successfully grasped and lifted. Now, navigate to the dining table in the living room to pick up the second remote control.", "next": {"skill": "navigate", "category": "remote control", "surface": "dining table", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 17
pick성공 90 스텝 · 그리퍼 전환 6
에이전트의 이유
I am standing at the dining table in the living room where the second remote control is located. I will now pick it up.
I am standing at the dining table in the living room where the second remote control is located. I will now pick it up.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "I am standing at the dining table in the living room where the second remote control is located. I will now pick it up.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 18
pick성공 83 스텝 · 그리퍼 전환 4
에이전트의 이유
The gripper is engaging the remote control on the dining table; continuing the pick to lift it.
The gripper is engaging the remote control on the dining table; continuing the pick to lift it.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "The gripper is engaging the remote control on the dining table; continuing the pick to lift it.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 19
pick성공 12 스텝 · 그리퍼 전환 0
에이전트의 이유
The gripper was reaching for the remote control on the armchair/seat but hasn't successfully grasped and lifted it yet. Retrying pick.
The gripper was reaching for the remote control on the armchair/seat but hasn't successfully grasped and lifted it yet. Retrying pick.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_2 |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "The gripper was reaching for the remote control on the armchair/seat but hasn't successfully grasped and lifted it yet. Retrying pick.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
턴 20
navigate도착 경로 9.588266436421733 m · 371 스텝
에이전트의 이유
According to the plan, the first target is the remote control placed on the armchair in the living room. I will navigate to the armchair in the living room.
According to the plan, the first target is the remote control placed on the armchair in the living room. I will navigate to the armchair in the living room.
| skill | navigate |
| category / surface / room | None / None / living room |
| 접지된 object_id | remotecontrol_dbbd4afce0b009e98224c7453fb4cfc5_1_0_7 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "According to the plan, the first target is the remote control placed on the armchair in the living room. I will navigate to the armchair in the living room.", "next": {"skill": "navigate", "category": "remote control", "surface": "armchair", "room": "living room"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] [ 0s– 52s] I picked up the cell phone from the dining table in the living room and carried it to the armchair in the living room, but I could not place it there. Afterwards I went over to look at where it had ended up.\n[context] [ 52s– 159s] I picked up remote control #1 from the dining table in the living room and placed it on the countertop in the kitchen.\n[context] [ 159s– 301s] I picked up the knife from the countertop in the kitchen and placed it on the dining table in the bedroom.\n[context] [ 301s– 434s] I picked up remote control #1 from the countertop in the kitchen and placed it on the armchair in the living room.\n[context] [ 434s– 529s] I picked up remote control #2 from the bed in the bedroom and placed it on the dining table in the living room.\n[plan] 1. [ ] pick up the remote control — on the armchair in the living room\n[plan] 2. [ ] pick up the remote control — on the dining table in the living room', 'Object names used in this house:\napple, armchair, basketball, bed, book, bottle, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dresser, egg, fridge, garbage can, house plant, key chain, knife, laptop, mug, painting, pan, paper towel roll, pen, pepper shaker, pillow, plate, potato, remote control, soap bottle, sofa, spoon, spray bottle, stool, television, toaster, vase, watch', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up all the remote controls I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
플랜 3 — rollforward-vis-pure · Pick up the ladle
| 질의 | Pick up the ladle |
| 전략 | rollforward-vis-pure · v1_train_3058__1 |
| 결과 | 성공 종료 done · 5/22턴 · 520/1500스텝 · $0.058 (5회) |
| navigate / pick 횟수 | 1 / 3 · 재질의 0 |
| GT 물체를 든 횟수 | 1/1 |
초기 계획(읽기 답)
- pick up the ladle — on the dining table in the kitchen
턴 전수 펼치기 (5턴)
턴 0
navigate도착 경로 8.922046951294524 m · 360 스텝
에이전트의 이유
Navigate to the ladle on the dining table in the kitchen to get within reach for picking it up.
Navigate to the ladle on the dining table in the kitchen to get within reach for picking it up.
| skill | navigate |
| category / surface / room | None / None / kitchen |
| 접지된 object_id | ladle_9c306e3043202395854ae4a3cba13e79_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{
  "note": null,
  "keep": "KEEP: none",
  "reasoning": "Navigate to the ladle on the dining table in the kitchen to get within reach for picking it up.",
  "next": {
    "skill": "navigate",
    "category": "ladle",
    "surface": "dining table",
    "room": "kitchen"
  }
}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Your memory frames:', '[m1]', '[m2]', '[m3]', '[m4]', '[m5]', '[m6]', '[m7]', '[m8]', 'Your current view:', '[F1]', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the ladle — on the dining table in the kitchen', 'Object names used in this house:\nalarm clock, apple, armchair, baseball bat, bed, book, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dish sponge, dresser, egg, floor lamp, fridge, garbage bag, garbage can, house plant, knife, ladle, laptop, lettuce, mug, newspaper, painting, pan, pen, pencil, pepper shaker, pillow, plate, pot, potato, remote control, salt shaker, shelving unit, soap bottle, sofa, spatula, spoon, statue, television, tennisracket, tomato, vase', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up the ladle', 'Reply with the JSON object only.'], 'n_images': 9}
턴 1
pick성공 66 스텝 · 그리퍼 전환 3
에이전트의 이유
The robot is positioned at the dining table in the kitchen right in front of the ladle. I will command the pick skill for the ladle.
The robot is positioned at the dining table in the kitchen right in front of the ladle. I will command the pick skill for the ladle.
| skill | pick |
| category / surface / room | ladle / None / None |
| 접지된 object_id | ladle_9c306e3043202395854ae4a3cba13e79_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | ladle_9c306e3043202395854ae4a3cba13e79_1_0_6 |
| 정책 프롬프트 | Pick up the ladle |
VLM 원문 응답
```json
{
  "note": null,
  "keep": "KEEP: none",
  "reasoning": "The robot is positioned at the dining table in the kitchen right in front of the ladle. I will command the pick skill for the ladle.",
  "next": {
    "skill": "pick",
    "category": "ladle",
    "surface": null,
    "room": null
  }
}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Your memory frames:', '[m1]', '[m2]', '[m3]', '[m4]', '[m5]', '[m6]', '[m7]', '[m8]', 'Frames captured while your previous subgoal was executing:', '[F1]', '[F2]', '[F3]', 'Your current view:', '[F4]', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the ladle — on the dining table in the kitchen', 'Object names used in this house:\nalarm clock, apple, armchair, baseball bat, bed, book, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dish sponge, dresser, egg, floor lamp, fridge, garbage bag, garbage can, house plant, knife, ladle, laptop, lettuce, mug, newspaper, painting, pan, pen, pencil, pepper shaker, pillow, plate, pot, potato, remote control, salt shaker, shelving unit, soap bottle, sofa, spatula, spoon, statue, television, tennisracket, tomato, vase', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up the ladle', 'Reply with the JSON object only.'], 'n_images': 12}
턴 2
pick성공 82 스텝 · 그리퍼 전환 6
에이전트의 이유
The gripper is closing around the ladle handle. I will continue the pick skill to lift the ladle.
The gripper is closing around the ladle handle. I will continue the pick skill to lift the ladle.
| skill | pick |
| category / surface / room | ladle / None / None |
| 접지된 object_id | ladle_9c306e3043202395854ae4a3cba13e79_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | ladle_9c306e3043202395854ae4a3cba13e79_1_0_6 |
| 정책 프롬프트 | Pick up the ladle |
VLM 원문 응답
```json
{
  "note": null,
  "keep": "KEEP: none",
  "reasoning": "The gripper is closing around the ladle handle. I will continue the pick skill to lift the ladle.",
  "next": {
    "skill": "pick",
    "category": "ladle",
    "surface": null,
    "room": null
  }
}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Your memory frames:', '[m1]', '[m2]', '[m3]', '[m4]', '[m5]', '[m6]', '[m7]', '[m8]', 'Frames captured while your previous subgoal was executing:', '[F1]', '[F2]', '[F3]', 'Your current view:', '[F4]', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the ladle — on the dining table in the kitchen', 'Object names used in this house:\nalarm clock, apple, armchair, baseball bat, bed, book, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dish sponge, dresser, egg, floor lamp, fridge, garbage bag, garbage can, house plant, knife, ladle, laptop, lettuce, mug, newspaper, painting, pan, pen, pencil, pepper shaker, pillow, plate, pot, potato, remote control, salt shaker, shelving unit, soap bottle, sofa, spatula, spoon, statue, television, tennisracket, tomato, vase', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up the ladle', 'Reply with the JSON object only.'], 'n_images': 12}
턴 3
pick성공 12 스텝 · 그리퍼 전환 0
에이전트의 이유
The gripper has closed around the ladle handle during this turn, but has not completed the lifting phase yet. Issuing pick again to complete the lift.
The gripper has closed around the ladle handle during this turn, but has not completed the lifting phase yet. Issuing pick again to complete the lift.
| skill | pick |
| category / surface / room | ladle / None / None |
| 접지된 object_id | ladle_9c306e3043202395854ae4a3cba13e79_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | ladle_9c306e3043202395854ae4a3cba13e79_1_0_6 |
| 정책 프롬프트 | Pick up the ladle |
VLM 원문 응답
```json
{
  "note": null,
  "keep": "KEEP: none",
  "reasoning": "The gripper has closed around the ladle handle during this turn, but has not completed the lifting phase yet. Issuing pick again to complete the lift.",
  "next": {
    "skill": "pick",
    "category": "ladle",
    "surface": null,
    "room": null
  }
}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Your memory frames:', '[m1]', '[m2]', '[m3]', '[m4]', '[m5]', '[m6]', '[m7]', '[m8]', 'Frames captured while your previous subgoal was executing:', '[F1]', '[F2]', '[F3]', 'Your current view:', '[F4]', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the ladle — on the dining table in the kitchen', 'Object names used in this house:\nalarm clock, apple, armchair, baseball bat, bed, book, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dish sponge, dresser, egg, floor lamp, fridge, garbage bag, garbage can, house plant, knife, ladle, laptop, lettuce, mug, newspaper, painting, pan, pen, pencil, pepper shaker, pillow, plate, pot, potato, remote control, salt shaker, shelving unit, soap bottle, sofa, spatula, spoon, statue, television, tennisracket, tomato, vase', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up the ladle', 'Reply with the JSON object only.'], 'n_images': 12}
턴 4
donedone
에이전트의 이유
The ladle is securely grasped and lifted in the robot's gripper, completing the goal.
The ladle is securely grasped and lifted in the robot's gripper, completing the goal.
| skill | done |
| category / surface / room | None / None / None |
| 접지된 object_id | None |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "keep": "KEEP: none", "reasoning": "The ladle is securely grasped and lifted in the robot's gripper, completing the goal.", "next": {"skill": "done", "category": null, "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Your memory frames:', '[m1]', '[m2]', '[m3]', '[m4]', '[m5]', '[m6]', '[m7]', '[m8]', 'Frames captured while your previous subgoal was executing:', '[F1]', '[F2]', '[F3]', 'Your current view:', '[F4]', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the ladle — on the dining table in the kitchen', 'Object names used in this house:\nalarm clock, apple, armchair, baseball bat, bed, book, bowl, box, butter knife, candle, cell phone, chair, countertop, credit card, cup, desk lamp, dining table, dish sponge, dresser, egg, floor lamp, fridge, garbage bag, garbage can, house plant, knife, ladle, laptop, lettuce, mug, newspaper, painting, pan, pen, pencil, pepper shaker, pillow, plate, pot, potato, remote control, salt shaker, shelving unit, soap bottle, sofa, spatula, spoon, statue, television, tennisracket, tomato, vase', 'Room names used in this house:\nbedroom, kitchen, living room', 'Goal: Pick up the ladle', 'Reply with the JSON object only.'], 'n_images': 12}
플랜 4 — blind · Pick up the remote control I moved earlier
| 질의 | Pick up the remote control I moved earlier |
| 전략 | blind · v1_train_573__2 |
| 결과 | 실패 종료 done · 2/22턴 · 128/1500스텝 · $0.008 (2회) |
| navigate / pick 횟수 | 0 / 1 · 재질의 0 |
| GT 물체를 든 횟수 | 0/1 |
초기 계획(읽기 답)
- pick up the remote control — on the bed in the bedroom
턴 전수 펼치기 (2턴)
턴 0
pick실패 128 스텝 · 그리퍼 전환 6
에이전트의 이유
We are already in front of the bed where the remote control is located. I will pick up the remote control.
We are already in front of the bed where the remote control is located. I will pick up the remote control.
| skill | pick |
| category / surface / room | remote control / None / None |
| 접지된 object_id | remotecontrol_bbeb7464bb8b20b11df78329c1bd9460_1_0_4 |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the remote control |
VLM 원문 응답
```json
{"note": null, "reasoning": "We are already in front of the bed where the remote control is located. I will pick up the remote control.", "next": {"skill": "pick", "category": "remote control", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the remote control — on the bed in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, basketball, bed, book, bowl, box, bread, cart, cell phone, chair, cloth, clothes dryer, countertop, credit card, desk lamp, dining table, dish sponge, dresser, egg, faucet, fridge, garbage can, house plant, key chain, laptop, lettuce, mug, painting, pan, paper towel roll, pen, pencil, pepper shaker, pillow, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, soap bottle, spatula, spray bottle, statue, teddy bear, television, tissue box, toilet, toilet paper, tomato, tv stand, vase, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the remote control I moved earlier', 'Reply with the JSON object only.'], 'n_images': 1}
턴 1
donedone
에이전트의 이유
The remote control has been successfully grasped and lifted into the air. The goal of picking up the remote control is complete.
The remote control has been successfully grasped and lifted into the air. The goal of picking up the remote control is complete.
| skill | done |
| category / surface / room | None / None / None |
| 접지된 object_id | None |
| 접지된 receptacle_id | None |
| 현재 방 | room_4 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": null, "reasoning": "The remote control has been successfully grasped and lifted into the air. The goal of picking up the remote control is complete.", "next": {"skill": "done", "category": null, "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[plan] 1. [ ] pick up the remote control — on the bed in the bedroom', 'Object names used in this house:\nCD, alarm clock, apple, basketball, bed, book, bowl, box, bread, cart, cell phone, chair, cloth, clothes dryer, countertop, credit card, desk lamp, dining table, dish sponge, dresser, egg, faucet, fridge, garbage can, house plant, key chain, laptop, lettuce, mug, painting, pan, paper towel roll, pen, pencil, pepper shaker, pillow, plate, plunger, pot, potato, remote control, salt shaker, shelving unit, side table, sink, soap bottle, spatula, spray bottle, statue, teddy bear, television, tissue box, toilet, toilet paper, tomato, tv stand, vase, watch', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the remote control I moved earlier', 'Reply with the JSON object only.'], 'n_images': 4}
플랜 5 — rollforward-v3 · Pick up the knife
| 질의 | Pick up the knife |
| 전략 | rollforward-v3 · v1_train_8287__1 |
| 결과 | 실패 종료 done · 10/22턴 · 1397/1500스텝 · $0.055 (10회) |
| navigate / pick 횟수 | 1 / 8 · 재질의 0 |
| GT 물체를 든 횟수 | 0/1 |
초기 계획(읽기 답)
- pick up the butter knife — on the countertop in the kitchen
턴 전수 펼치기 (10턴)
턴 0
navigate도착 경로 9.54156268545141 m · 373 스텝
에이전트의 이유
The goal is to pick up the knife (butter knife). According to context, it is on the kitchen countertop. I need to navigate to the kitchen countertop first.
The goal is to pick up the knife (butter knife). According to context, it is on the kitchen countertop. I need to navigate to the kitchen countertop first.
| skill | navigate |
| category / surface / room | None / None / kitchen |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_7 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": "[context] I am currently in the living room next to the table with the apple.\n[plan]\n1. [ ] pick up the butter knife — on the countertop in the kitchen", "reasoning": "The goal is to pick up the knife (butter knife). According to context, it is on the kitchen countertop. I need to navigate to the kitchen countertop first.", "next": {"skill": "navigate", "category": "butter knife", "surface": "countertop", "room": "kitchen"}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] I started near a dining table holding a cup, bowl, laptop, statue, pen, remote control, and tissue box. I moved the cup from the dining table onto the desk (which held a table lamp, CDs, a cell phone, a vase, a statue, a tissue box, and an adjacent house plant). I placed a basketball on the dresser (near a bed with a pillow and tennisracket), entered the bathroom (with a toilet, plunger, and sink with a sponge), and moved a box from the floor into the sink. I then stored the remote control in a desk drawer (which already contained a pencil). Next, I retrieved the box from the bathroom sink and placed it on the desk. Afterwards, I went to the kitchen countertop (which held a microwaveoven, wine bottle, cup, spatula, credit card, egg, spoon, butter knife, plate, and apple), picked up the apple, and placed it on a table in the living area (which held a candle, cell phone, key chain, and other small items).\n[plan] 1. [ ] pick up the butter knife — on the countertop in the kitchen', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 1}
턴 1
pick실패 128 스텝 · 그리퍼 전환 5
에이전트의 이유
I have navigated to the kitchen countertop where the knife should be located. I will now attempt to pick the knife.
I have navigated to the kitchen countertop where the knife should be located. I will now attempt to pick the knife.
| skill | pick |
| category / surface / room | knife / None / None |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the knife |
VLM 원문 응답
```json
{"note": "[context] Navigated to kitchen countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen", "reasoning": "I have navigated to the kitchen countertop where the knife should be located. I will now attempt to pick the knife.", "next": {"skill": "pick", "category": "knife", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] I am currently in the living room next to the table with the apple.\n[plan]\n1. [ ] pick up the butter knife — on the countertop in the kitchen', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}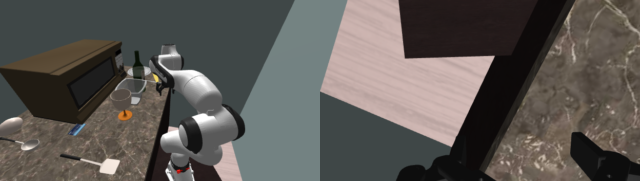
턴 2
pick실패 128 스텝 · 그리퍼 전환 4
에이전트의 이유
The robot is at the countertop with the knife in view/reach. I will command pick(knife) to grasp and lift it.
The robot is at the countertop with the knife in view/reach. I will command pick(knife) to grasp and lift it.
| skill | pick |
| category / surface / room | knife / None / None |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the knife |
VLM 원문 응답
```json
{"note": "[context] Navigated to kitchen countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Attempting pick on knife.", "reasoning": "The robot is at the countertop with the knife in view/reach. I will command pick(knife) to grasp and lift it.", "next": {"skill": "pick", "category": "knife", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] Navigated to kitchen countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}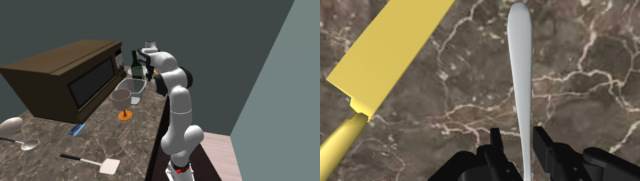
턴 3
pick실패 128 스텝 · 그리퍼 전환 7
에이전트의 이유
The goal is to pick up the knife. The gripper grasped the butter knife (white) instead of the yellow knife on the countertop. I need to issue pick(knife) to target the yellow knife.
The goal is to pick up the knife. The gripper grasped the butter knife (white) instead of the yellow knife on the countertop. I need to issue pick(knife) to target the yellow knife.
| skill | pick |
| category / surface / room | knife / None / None |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the knife |
VLM 원문 응답
```json
{
  "note": "[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Gripper grasped the butter knife instead of the knife; yellow knife is still on countertop.",
  "reasoning": "The goal is to pick up the knife. The gripper grasped the butter knife (white) instead of the yellow knife on the countertop. I need to issue pick(knife) to target the yellow knife.",
  "next": {
    "skill": "pick",
    "category": "knife",
    "surface": null,
    "room": null
  }
}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] Navigated to kitchen countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Attempting pick on knife.', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}
턴 4
pick실패 128 스텝 · 그리퍼 전환 13
에이전트의 이유
The yellow knife is directly in front of the gripper on the countertop. I will pick the knife.
The yellow knife is directly in front of the gripper on the countertop. I will pick the knife.
| skill | pick |
| category / surface / room | knife / None / None |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the knife |
VLM 원문 응답
```json
{"note": "[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Yellow knife is on the countertop within reach.", "reasoning": "The yellow knife is directly in front of the gripper on the countertop. I will pick the knife.", "next": {"skill": "pick", "category": "knife", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Gripper grasped the butter knife instead of the knife; yellow knife is still on countertop.', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}
턴 5
pick실패 128 스텝 · 그리퍼 전환 13
에이전트의 이유
The gripper is reaching towards the knife on the countertop but has not yet grasped and lifted it. Continuing pick execution.
The gripper is reaching towards the knife on the countertop but has not yet grasped and lifted it. Continuing pick execution.
| skill | pick |
| category / surface / room | knife / None / None |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the knife |
VLM 원문 응답
```json
{"note": "[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Yellow knife is on countertop, pick attempt in progress.", "reasoning": "The gripper is reaching towards the knife on the countertop but has not yet grasped and lifted it. Continuing pick execution.", "next": {"skill": "pick", "category": "knife", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Yellow knife is on the countertop within reach.', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}
턴 6
pick실패 128 스텝 · 그리퍼 전환 9
에이전트의 이유
The gripper is positioning around the knife handle but has not grasped and lifted it yet. Issuing pick(knife) again.
The gripper is positioning around the knife handle but has not grasped and lifted it yet. Issuing pick(knife) again.
| skill | pick |
| category / surface / room | knife / None / None |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the knife |
VLM 원문 응답
```json
{
  "note": "[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Attempted pick(knife); gripper is aligning near knife handle, not lifted yet.",
  "reasoning": "The gripper is positioning around the knife handle but has not grasped and lifted it yet. Issuing pick(knife) again.",
  "next": {
    "skill": "pick",
    "category": "knife",
    "surface": null,
    "room": null
  }
}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Yellow knife is on countertop, pick attempt in progress.', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}
턴 7
pick실패 128 스텝 · 그리퍼 전환 8
에이전트의 이유
The gripper has closed around the knife but has not lifted it up yet. Continue executing pick(knife).
The gripper has closed around the knife but has not lifted it up yet. Continue executing pick(knife).
| skill | pick |
| category / surface / room | knife / None / None |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the knife |
VLM 원문 응답
```json
{"note": "[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Attempted pick(knife); gripper is closed around the knife, executing pick.", "reasoning": "The gripper has closed around the knife but has not lifted it up yet. Continue executing pick(knife).", "next": {"skill": "pick", "category": "knife", "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Attempted pick(knife); gripper is aligning near knife handle, not lifted yet.', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}
턴 8
pick실패 128 스텝 · 그리퍼 전환 8
에이전트의 이유
The gripper is holding the knife, but it has not been fully lifted yet. Issuing pick(knife) again to complete the lift.
The gripper is holding the knife, but it has not been fully lifted yet. Issuing pick(knife) again to complete the lift.
| skill | pick |
| category / surface / room | knife / None / None |
| 접지된 object_id | knife_ddd3867ee8b360621e97c1da8ea8906d_1_0_6 |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | Pick up the knife |
VLM 원문 응답
```json
{
  "note": "[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Gripper is grasping the knife, lift in progress.",
  "reasoning": "The gripper is holding the knife, but it has not been fully lifted yet. Issuing pick(knife) again to complete the lift.",
  "next": {
    "skill": "pick",
    "category": "knife",
    "surface": null,
    "room": null
  }
}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Attempted pick(knife); gripper is closed around the knife, executing pick.', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}
턴 9
donedone
에이전트의 이유
The knife is clearly grasped and lifted in the gripper, completing the goal.
The knife is clearly grasped and lifted in the gripper, completing the goal.
| skill | done |
| category / surface / room | None / None / None |
| 접지된 object_id | None |
| 접지된 receptacle_id | None |
| 현재 방 | room_6 |
| 들고 있는 물체 | None |
| 정책 프롬프트 | — |
VLM 원문 응답
```json
{"note": "[context] In kitchen at countertop.\n[plan]\n1. [x] pick up the knife — on the countertop in the kitchen\n- Knife is picked and held in the gripper.", "reasoning": "The knife is clearly grasped and lifted in the gripper, completing the goal.", "next": {"skill": "done", "category": null, "surface": null, "room": null}}
```
이 턴에 VLM 이 받은 프롬프트 전문
{'texts': ['Frames captured while your previous subgoal was executing:', 'Your current view:', 'Your notes so far:\nHere are my running notes from the episode, written by me while acting (subgoal by subgoal):\n\n[context] In kitchen at countertop.\n[plan]\n1. [ ] pick up the knife — on the countertop in the kitchen\n- Gripper is grasping the knife, lift in progress.', 'Object names used in this house:\nCD, alarm clock, apple, armchair, basketball, bed, book, bowl, box, butter knife, candle, cart, cell phone, chair, countertop, credit card, cup, desk, desk lamp, dining table, dish sponge, dog bed, dresser, egg, faucet, fork, fridge, garbage bag, garbage can, house plant, key chain, knife, ladle, laptop, microwave, mug, painting, paper towel roll, pen, pencil, pillow, plate, plunger, remote control, sink, sofa, spatula, spray bottle, statue, stool, television, tennisracket, tissue box, toilet, toilet paper, tv stand, vase, watch, wine bottle', 'Room names used in this house:\nbedroom, bathroom, kitchen, living room', 'Goal: Pick up the knife', 'Reply with the JSON object only.'], 'n_images': 4}