writer 입력 ablation — 시험 실행 결과
1숫자
맞은 질의 수 / 전체 질의 수입니다. "논문 당시"는 같은 녹화·같은 모델(gemini-3.7-flash)의 보관된 결과입니다. exo 10장 조건은 writer가 있는 세 방법만 돌렸습니다.
| 과제 | 방법 | 논문 당시 | v2 exo 4장 | v2 exo 10장 | v2 exo+wrist 10장 |
|---|---|---|---|---|---|
| finding | No Memory | 1/8 | 2/8 | — | 1/8 |
| finding | GT Action Log | 4/8 | 5/8 | — | 5/8 |
| finding | Uniform Frames | 5/8 | 5/8 | — | 4/8 |
| finding | MEM^R | 5/8 | 3/8 | 1/8 | 5/8 |
| finding | MemER^R | 2/8 | 5/8 | 5/8 | 4/8 |
| finding | R&R Agent | 3/8 | 3/8 | 3/8 | 1/8 |
| restore | No Memory | 0/4 | 0/4 | — | 0/4 |
| restore | GT Action Log | 3/4 | 4/4 | — | 4/4 |
| restore | Uniform Frames | 0/4 | 2/4 | — | 1/4 |
| restore | MEM^R | 1/4 | 0/4 | 1/4 | 1/4 |
| restore | MemER^R | 0/4 | 1/4 | 1/4 | 1/4 |
| restore | R&R Agent | 0/4 | 1/4 | 2/4 | 0/4 |
| routine | No Memory | 0/3 | 0/3 | — | 0/3 |
| routine | GT Action Log | 1/3 | 1/3 | — | 1/3 |
| routine | Uniform Frames | 2/3 | 0/3 | — | 0/3 |
| routine | MEM^R | 1/3 | 1/3 | 1/3 | 1/3 |
| routine | MemER^R | 3/3 | 2/3 | 2/3 | 2/3 |
| routine | R&R Agent | 1/3 | 2/3 | 1/3 | 1/3 |
| resume | No Memory | 0/1 | 0/1 | — | 0/1 |
| resume | GT Action Log | 1/1 | 1/1 | — | 1/1 |
| resume | Uniform Frames | 0/1 | 0/1 | — | 1/1 |
| resume | MEM^R | 1/1 | 1/1 | 0/1 | 1/1 |
| resume | MemER^R | 0/1 | 0/1 | 0/1 | 0/1 |
| resume | R&R Agent | 1/1 | 1/1 | 0/1 | 1/1 |
비용 (괄호는 API 호출 수)
| 조건 | Finding | Restore | Routine | Resume | 합계 |
|---|---|---|---|---|---|
| exo_f4 | $1.05 (102) | $0.76 (57) | $0.64 (54) | $0.38 (42) | $2.82 |
| exo_f10 | $1.01 (78) | $0.65 (45) | $0.62 (45) | $0.54 (39) | $2.82 |
| wrist_f10 | $1.45 (102) | $0.87 (57) | $0.67 (54) | $0.58 (42) | $3.57 |
writer 한 번에 들어가는 이미지: exo 4장 조건은 640×480 4장, exo 10장은 640×480 10장, exo+wrist 10장은 960×480 10장(MemER^R은 보관 프레임 8장이 더 붙어 최대 18장).
2VLM에 들어가는 입력
아래는 API 호출 없이 실제 실행 코드를 그대로 돌려 뽑은 프롬프트 전문입니다(이미지는 크기만 표시).
MEM^R writer가 받는 입력 전문 (v2, 첫 30초 창)
같은 입력의 논문 당시(v1) 전문
R&R Agent reader가 받는 입력 전문 (v2, 가짜 기억으로 채운 형식 예시)
No Memory reader가 받는 입력 전문 (v2)
논문 당시와 달라진 입력
| 항목 | 논문 당시 (v1) | 지금 (v2) |
|---|---|---|
| 물체 이름 목록 | atomizer, boiler, cooking pan, fabric, irish potato, knickknack, soapdispenser, toilet tissue … | spray bottle, kettle, pan, cloth, potato, soap bottle, toilet paper … (질의문이 쓰는 단어) |
| 가구 목록 | dining table 포함, side table·fridge·laundry basket 없음 | table, side table, fridge, laundry basket 포함 (19종 + floor) |
| writer별 목록 | MEM^R·R&R Agent만 목록을 받고 MemER^R은 받지 않음 | 세 writer가 같은 목록을 받음 |
| 30초 창의 4장 | 0, 10, 20, 30초 | 0, 7.5, 15, 22.5초 |
| Routine 질의 프레임 | 이 녹화에서는 8,071번 프레임(녹화는 8,728프레임) | 실제 녹화 끝(8,727번) |
| Uniform Frames | 8장 중 마지막 장이 질의 프레임과 같은 장 | 질의 프레임과 겹치지 않는 8장 |
exo만 줄 때와 exo+wrist를 줄 때의 한 장
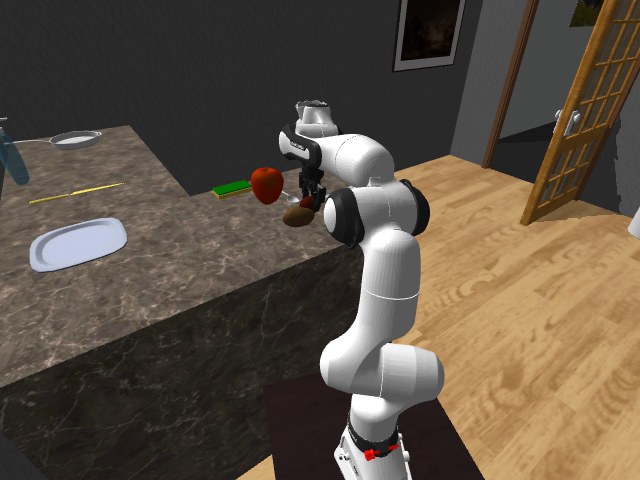
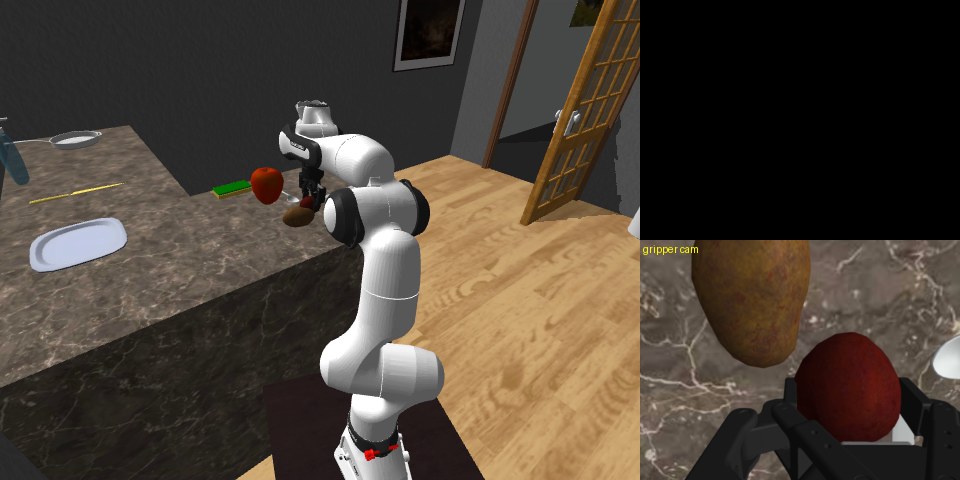
3사례: 입력 → reasoning → 출력 → 채점
사례 A. 같은 답인데 논문 당시에는 오답, 지금은 정답 (Restore)
질의: Pick up the pen and place it in or on where it first was, then pick up the remote control and place it in or on where it first was 방법: GT Action Log
| 정답(채점 기준) | 모델 출력과 reasoning | 채점 | |
|---|---|---|---|
| 논문 당시 | [{"category": "pen", "now": {"room": null, "surface": "sofa"}, "original": {"room": null, "surface": "dining table"}}, {"category": "remote control", "now": {"room": null, "surface": "dining table"}, "original": {"room": null, "surface": "sofa"}}] | {"selections": [{"category": "pen", "now": {"room": "living room", "surface": "sofa"}, "original": {"room": "living room", "surface": "dining table"}}, {"category": "remote control", "now": {"room": "bedroom", "surface": "dining table"}, "original": {"room": "living room", "surface": "sofa"}}], "abstain": false}The pen was moved from the dining table in the living room to the sofa in the living room. Its initial location was the dining table in the living room, and it is currently on the sofa in the living room. The remote control was moved from the sofa in the living room to the dining table in the bedroom. Its initial location was the sofa in the living room, and it is currently on the dining table in the bedroom. | loc 1 · place 0 · abstain 0 · parse_ok 1 · now/orig loc 1/1 · $0.0035 · 3.1s |
| v2 exo_f4 | [{"category": "pen", "now": {"room": "living room", "surface": "sofa", "aliases": ["couch", "loveseat", "settee"]}, "original": {"room": "living room", "surface": "table", "aliases": ["dining table", "kitchen table", "desk"]}, "alts": []}, {"category": "remote control", "now": {"room": "bedroom", "surface": "table", "aliases": ["dining table", "kitchen table"]}, "original": {"room": "living room", "surface": "sofa", "aliases": ["couch", "loveseat", "settee"]}, "alts": []}] | {"selections": [{"category": "pen", "now": {"room": "living room", "surface": "sofa"}, "original": {"room": "living room", "surface": "table"}}, {"category": "remote control", "now": {"room": "bedroom", "surface": "table"}, "original": {"room": "living room", "surface": "sofa"}}], "abstain": false}The pen was moved from the dining table in the living room to the sofa in the living room, so it is currently on the sofa in the living room and was first on the table in the living room. The remote control was moved from the sofa in the living room to the dining table in the bedroom, so it is currently on the table in the bedroom and was first on the sofa in the living room. | place_set 1 |
"room": null). 모델은 방과 가구를 모두 맞혔는데 place 점수가 0이었습니다. v2는 방 이름을 채웠고 같은 답이 정답으로 채점됩니다. 정답을 그대로 읽어 주는 GT Action Log가 이 녹화에서 3/4 → 4/4가 된 이유입니다.사례 B. writer가 물체를 다르게 불러서 틀림 (Finding, 감자)
로봇이 실제로 옮긴 것은 감자입니다(조리대 → 식탁). 조리대에는 사과와 토마토도 같이 있었습니다.
질의: Pick up the potato I moved earlier 방법: R&R Agent
| 정답(채점 기준) | 모델 출력과 reasoning | 채점 | |
|---|---|---|---|
| 논문 당시 | [{"category": "irish potato", "room": "kitchen", "surface": "dining table", "hidden": false, "unlabeled": false}] | {"selections": [{"category": "irish potato", "room": "kitchen", "surface": "dining table"}], "abstain": false}The robot picked up the potato (noted as a tomato in some caption logs) from the kitchen countertop at t=450s and placed it on the dining table at t=510s (IMG 60). | loc 1 · place 1 · abstain 0 · parse_ok 1 · $0.0119 · 9.4s |
| v2 exo_f4 | [{"category": "potato", "room": "kitchen", "surface": "table", "aliases": ["dining table", "kitchen table", "desk"], "alts": [], "hidden": false, "unlabeled": false}] | {"selections": [{"category": "potato", "room": "kitchen", "surface": "countertop"}], "abstain": false}The potato was located on the kitchen countertop alongside other items (IMG 69, IMG 71) and remains there. | place_set 0 |
| v2 exo_f10 | [{"category": "potato", "room": "kitchen", "surface": "table", "aliases": ["dining table", "kitchen table", "desk"], "alts": [], "hidden": false, "unlabeled": false}] | {"selections": [{"category": "potato", "room": "kitchen", "surface": "table"}], "abstain": false}At t=510s, the potato was placed on the dining table in the kitchen, where it remains. | place_set 1 |
| v2 wrist_f10 | [{"category": "potato", "room": "kitchen", "surface": "table", "aliases": ["dining table", "kitchen table", "desk"], "alts": [], "hidden": false, "unlabeled": false}] | {"selections": [{"category": "potato", "room": "kitchen", "surface": "countertop"}], "abstain": false}The potato was seen on the kitchen countertop alongside the tomato and apple (IMG 69, IMG 71). While the robot picked up and moved the tomato to the dining table, the potato remained on the countertop. | place_set 0 |
MEM^R writer가 쓴 최종 기억 (같은 녹화, 조건별):
| 조건 | 기억 전문 |
|---|---|
| 논문 당시 (exo 4장) | I started in the kitchen/dining area, observing a wine bottle, tomato, bread, lettuce, bowl, and bottle on the dining table, plus a plate and apple on the countertop. In the living room, I saw a coffee table with a house plant and bowl, a yellow sofa, a floor lamp, a dark armchair, and a tv stand with a television and knickknacks. In the study room, I saw a desk with a basketball and chairs, and a dresser with a table lamp, pen, and remote control. I moved a yellow knickknack from the tv stand into a drawer of the dresser in the study room and closed it. Next, I picked up a butter knife from the armchair in the living room and placed it onto the dining table. Then, I took an irish potato from the kitchen countertop (which also held a cooking pan, sponge, soapdispenser, vase, and spoon) and placed it onto the dining table. |
| v2 exo_f4 | In the kitchen, a table initially held a wine bottle, tomato, bread, lettuce, a knife, a bowl, and a bottle; a countertop held a vase, apple, potato, plate, pan, soap bottle, spoon, sponge, and butter knife. In the living room, a round table held a house plant, bowl, and statue, a yellow sofa held a pencil, and a tv stand held a television and candle. In the bedroom, a table held a basketball and house plant, and a dresser (topped with a desk lamp, pen, and remote control) holds the yellow alarm clock inside its closed drawer. After placing the butter knife from the living room armchair onto the kitchen table, I picked up the apple from the kitchen countertop and placed it on the kitchen table. |
| v2 exo_f10 | In the kitchen, a table initially held a wine bottle, tomato, bread, lettuce, bottle, and a bowl with a spoon, while a countertop held a vase, tomato, potato, spoon, plate, soap bottle, pan, and sponge. Earlier, I moved a knife to a living room armchair, moved an alarm clock from the tv stand into the closed top drawer of a bedroom dresser, and returned the knife to the kitchen table. Most recently, after carrying the tomato from the kitchen countertop toward the doorway, I turned back into the kitchen and placed the tomato onto the kitchen table. |
| v2 wrist_f10 | I picked up a butter knife from the kitchen table (which held a wine bottle, tomato, bread, lettuce, bottle, bowl, another butter knife, and a chair; the countertop held a plate, pan, potato, tomato, apple, sponge, spoon, knife, vase, and soap bottle) and placed it on an armchair in the living room. In the living room (furnished with a sofa, armchair, floor lamp, a table with a house plant and bowl, and a tv stand with a television and candle), I picked up a plunger from the tv stand, carried it into the bedroom (which has a table with a basketball, chairs, a house plant, and a dresser with a desk lamp), placed it into the top drawer of the dresser (which contained a pen), and closed the drawer. I returned to the living room armchair, picked up the butter knife, and brought it back to the kitchen table. Then I picked up a tomato from the kitchen countertop and placed it on the kitchen table. |
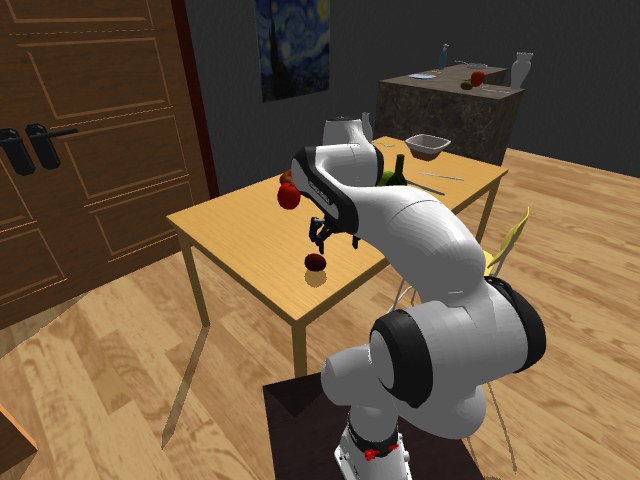
사례 C. 정답이 "vase"인 물체를 어떤 writer도 vase라고 부르지 않음 (Finding)
질의: Pick up the vase I moved earlier 방법: MEM^R
| 정답(채점 기준) | 모델 출력과 reasoning | 채점 | |
|---|---|---|---|
| 논문 당시 | [{"category": "vase", "room": "bedroom", "surface": "dresser", "hidden": true, "unlabeled": false}] | {"selections": [], "abstain": true}The memory summary records moving a knickknack, a butter knife, and an irish potato, but no vase was ever moved during the episode. | loc 0 · place 0 · abstain 1 · parse_ok 1 · $0.0031 · 2.6s |
| v2 exo_f4 | [{"category": "vase", "room": "bedroom", "surface": "dresser", "aliases": ["chest of drawers", "drawers", "chest", "cabinet"], "alts": [], "hidden": true, "unlabeled": false}] | {"selections": [], "abstain": true}The memory summary records moving a butter knife and an apple, but no vase was ever moved during the episode. Therefore, the request refers to an action that did not occur. | place_set 0 |
| v2 exo_f10 | [{"category": "vase", "room": "bedroom", "surface": "dresser", "aliases": ["chest of drawers", "drawers", "chest", "cabinet"], "alts": [], "hidden": true, "unlabeled": false}] | {"selections": [], "abstain": true}The memory summary details movements of a knife, an alarm clock, and a tomato. No vase was moved during the episode, making it impossible to identify 'the vase I moved earlier'. | place_set 0 |
| v2 wrist_f10 | [{"category": "vase", "room": "bedroom", "surface": "dresser", "aliases": ["chest of drawers", "drawers", "chest", "cabinet"], "alts": [], "hidden": true, "unlabeled": false}] | {"selections": [], "abstain": true}The memory summary records moving a butter knife, a plunger, and a tomato, but no vase was ever moved during the episode. | place_set 0 |
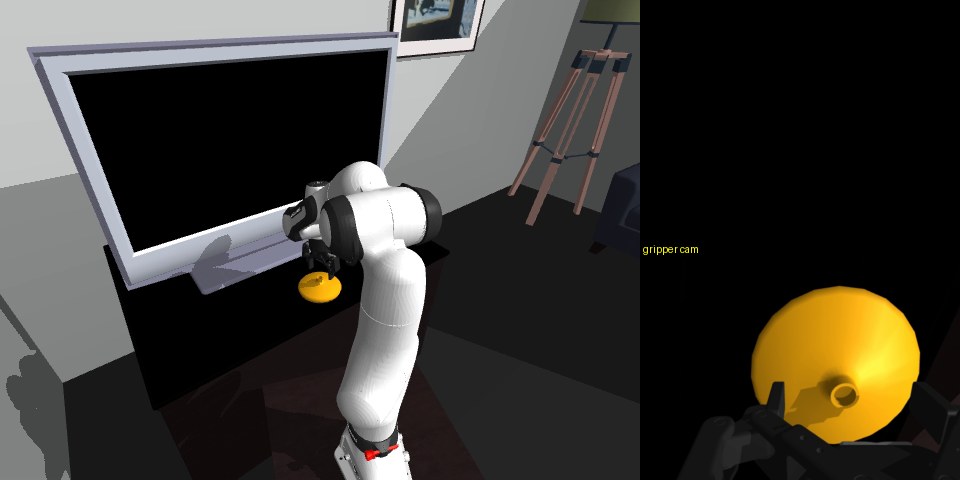
사례 D. Routine: 논문 당시 오답, 지금 정답
질의: Put the hand towel on the countertop away. 방법: R&R Agent
| 정답(채점 기준) | 모델 출력과 reasoning | 채점 | |
|---|---|---|---|
| 논문 당시 | {"store": [{"category": "hand towel", "room": "living room", "surface": "dining table", "instances": [{"room": "living room", "surface": "dining table", "uid": "diningtable_9c02a064c4b425976de085d4eaaa59cb_1_0_7"}]}], "leave": [], "expect": "store"} | {"selections": [{"category": "hand towel", "room": "bedroom", "surface": "desk"}], "abstain": false}Based on prior actions in memory, items of fabric/towels from countertops are consistently placed on the desk in the bedroom. | loc 0 · place 0 · any 0 · class 0 · abstain 0 · parse_ok 1 · writer v2 · $0.0120 · 23.8s |
| v2 exo_f4 | {"store": [{"category": "hand towel", "room": "living room", "surface": "table", "aliases": ["dining table", "kitchen table"], "alts": [], "instances": [{"room": "living room", "surface": "table", "aliases": ["dining table", "kitchen table"]}]}], "leave": [], "expect": "store"} | {"selections": [{"category": "hand towel", "room": "living room", "surface": "table"}], "abstain": false}The user instructed to put the clothes/cloths from the kitchen countertop onto the dining table, which is in the living room. | place_set 1 |
| v2 exo_f10 | {"store": [{"category": "hand towel", "room": "living room", "surface": "table", "aliases": ["dining table", "kitchen table"], "alts": [], "instances": [{"room": "living room", "surface": "table", "aliases": ["dining table", "kitchen table"]}]}], "leave": [], "expect": "store"} | {"selections": [{"category": "hand towel", "room": "living room", "surface": "table"}], "abstain": false}At t=0s, the user instructed to put clothes/cloths from the countertop onto the dining table. The robot previously moved cloths from the kitchen countertop to the table in the living room (t=90s, 180s, 270s, and seen on the table at t=300s in IMG 48). | place_set 1 |
| v2 wrist_f10 | {"store": [{"category": "hand towel", "room": "living room", "surface": "table", "aliases": ["dining table", "kitchen table"], "alts": [], "instances": [{"room": "living room", "surface": "table", "aliases": ["dining table", "kitchen table"]}]}], "leave": [], "expect": "store"} | {"selections": [{"category": "hand towel", "room": "living room", "surface": "table"}], "abstain": false}At t=0s, the user instructed to put clothes/cloths from the kitchen countertop onto the dining table, which is located in the living room. The robot subsequently placed the cloths onto the table in the living room. | place_set 1 |
논문 당시에는 식탁을 "bedroom의 desk"로 답했고, 지금은 세 조건 모두 "living room의 table"로 답합니다. 녹화 1개라 무엇 때문인지는 단정할 수 없습니다.
사례 E. Resume: 바뀌지 않은 오답
질의: You were interrupted earlier. Go back and finish what you were doing. 방법: MemER^R
| 정답(채점 기준) | 모델 출력과 reasoning | 채점 | |
|---|---|---|---|
| 논문 당시 | {"pending": [{"utterance": "Pick up four of the eggs from the dresser and place them into the basket.", "r": 3}], "finished_texts": ["Pick up three of the mugs from the dining table and place them in or on the tv stand.", "Hold on — go check whether the plate is still on the dining table in the living room first.", "go check whether the plate is still on the dining table in the living room"]} | {"unfinished": [{"task": "Pick up three of the mugs from the dining table and place them in or on the tv stand.", "remaining": 1}, {"task": "Pick up four of the eggs from the dresser and place them into the basket.", "remaining": 2}], "abstain": false}The robot was tasked with moving 3 mugs from the dining table to the TV stand. It moved 1 mug before checking the plate, and moved a 2nd mug after resuming, leaving 1 mug remaining before it was given the egg task. For the egg task, the robot was asked to place 4 eggs into the basket; as seen in the basket at the end of the episode, 2 eggs have been placed inside, leaving 2 eggs remaining. | resume_ok 0 · slot 0.0 · tasks_ok 0 · remaining_ok 0 · named_finished 1 · abstain 0 · parse_ok 1 · $0.0153 · 20.2s |
| v2 exo_f4 | {"pending": [{"utterance": "Pick up four of the eggs from the dresser and place them into the basket.", "r": 3}], "finished_texts": ["Pick up three of the mugs from the dining table and place them in or on the tv stand.", "Hold on — go check whether the plate is still on the dining table in the living room first.", "go check whether the plate is still on the dining table in the living room"]} | {"unfinished": [{"task": "Pick up three of the mugs from the dining table and place them in or on the tv stand.", "remaining": 1}, {"task": "Pick up four of the eggs from the dresser and place them into the basket.", "remaining": 4}], "abstain": false}The robot was tasked with moving three mugs from the dining table to the TV stand. It moved one mug before being interrupted to check the plate, then resumed and moved a second mug by t=255s before receiving a new command at t=260s. Thus, 1 mug remains for the first command. For the egg task, the robot was asked to place four eggs into the basket; it only transported the first egg to the basket and was stopped before successfully finishing and depositing any eggs, leaving all 4 eggs remaining. | resume_ok 0 |
| v2 exo_f10 | {"pending": [{"utterance": "Pick up four of the eggs from the dresser and place them into the basket.", "r": 3}], "finished_texts": ["Pick up three of the mugs from the dining table and place them in or on the tv stand.", "Hold on — go check whether the plate is still on the dining table in the living room first.", "go check whether the plate is still on the dining table in the living room"]} | {"unfinished": [{"task": "Pick up three of the mugs from the dining table and place them in or on the tv stand.", "remaining": 1}, {"task": "Pick up four of the eggs from the dresser and place them into the basket.", "remaining": 3}], "abstain": false}Command 1 required moving three mugs from the dining table to the TV stand. The robot placed the first mug, was interrupted to check the plate (which it did), resumed and placed the second mug, but was interrupted by Command 4 before picking up the third mug. Thus, 1 mug remains for Command 1. Command 4 asked to place four eggs into the basket; the robot successfully moved only 1 egg before being stopped, leaving 3 eggs remaining. | resume_ok 0 |
| v2 wrist_f10 | {"pending": [{"utterance": "Pick up four of the eggs from the dresser and place them into the basket.", "r": 3}], "finished_texts": ["Pick up three of the mugs from the dining table and place them in or on the tv stand.", "Hold on — go check whether the plate is still on the dining table in the living room first.", "go check whether the plate is still on the dining table in the living room"]} | {"unfinished": [{"task": "Pick up three of the mugs from the dining table and place them in or on the tv stand.", "remaining": 1}, {"task": "Pick up four of the eggs from the dresser and place them into the basket.", "remaining": 2}], "abstain": false}Command 1 required placing 3 mugs from the dining table onto the TV stand. The robot placed the first mug (around t=150s) and the second mug (around t=261s), but was interrupted by Command 4 before fetching the third mug, leaving 1 mug remaining. Command 2 was a quick check interruption that was completed. Command 4 required moving 4 eggs from the dresser to the basket; by t=348s, the robot had placed 2 eggs into the basket, leaving 2 eggs remaining. | resume_ok 0 |
MemER^R은 논문 당시와 같은 방식으로 틀립니다(이미 끝난 머그 과제를 남은 일로 셈).
4이전에 비해 확인된 개선과 확인하지 못한 것
| 항목 | 이 실행에서 확인한 것 |
|---|---|
| 어휘 | reader가 출력한 가구 단어 308개가 전부 목록 안의 단어(table 164, countertop 67, sofa 43, dresser 13, desk 10, tv stand 6, side table 3 …). reasoning에서는 "dining table"이라고 쓰면서도 출력은 "table"로 냈습니다. 버려진 단어 0. |
| 정답 라벨 | 방 이름이 비어 있던 Restore 정답이 채워져, 맞은 답이 오답 처리되던 사례가 사라짐(사례 A). |
| 입력 조건 | 세 writer가 같은 이름 목록을 받고, 30초 창의 프레임이 균등 간격이며, Routine 질의 프레임이 실제 녹화 끝임을 프롬프트 전문에서 확인. |
| 정확도 | 판단 불가. 녹화 1개에서는 reader 흔들림(1–2문항)과 구분되지 않습니다. |
| exo 10장·wrist의 효과 | 판단 불가. 이 녹화에서는 장수를 늘리거나 wrist를 넣어도 writer가 감자를 다른 이름으로 적었습니다(사례 B). |
| 남은 문제 | 생김새가 이름과 다른 물체(사례 C의 vase). 물체 모델별로 점검이 필요합니다. |
5다음
- 본 실행(job 190516)은 2시간 돌고 멈춘 상태입니다. 약 $42를 썼고 끝난 녹화는 저장되어 있습니다. 이어서 돌릴지는 결정이 필요합니다.
- vase처럼 이름과 생김새가 다른 물체 모델이 더 있는지 점검합니다(정답 물체를 writer들이 어떤 단어로 적었는지 논문 본 런 기억에서 집계).